
ESP8266 NodeMCU WiFi Controlled Robot Car 2WD DIY Kit
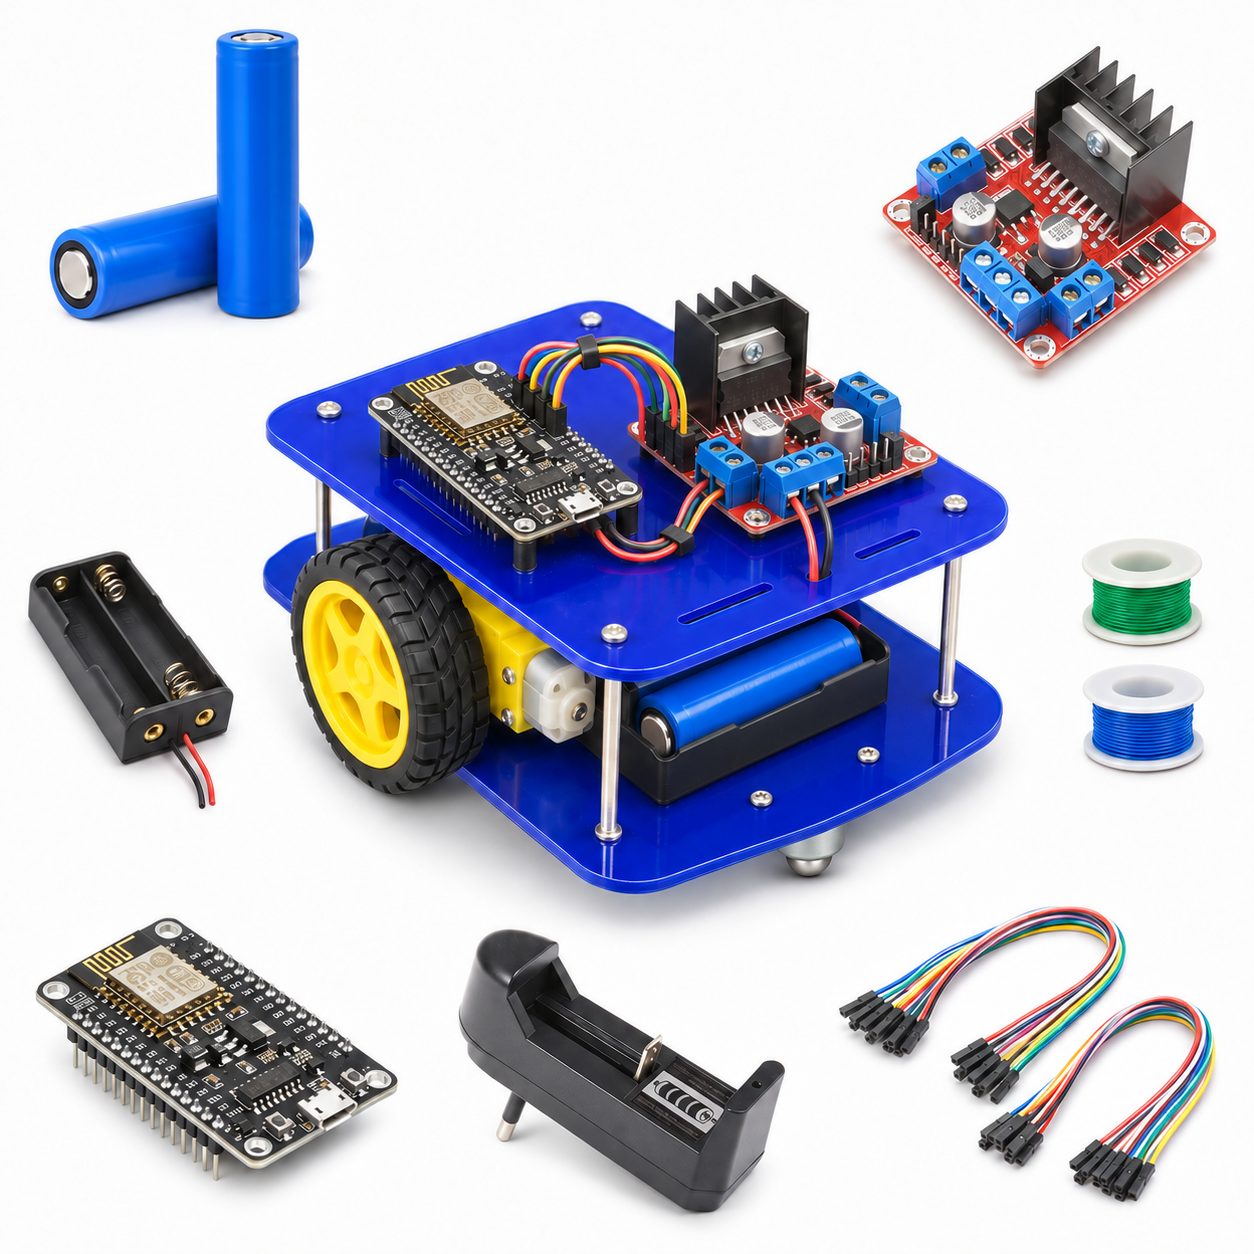
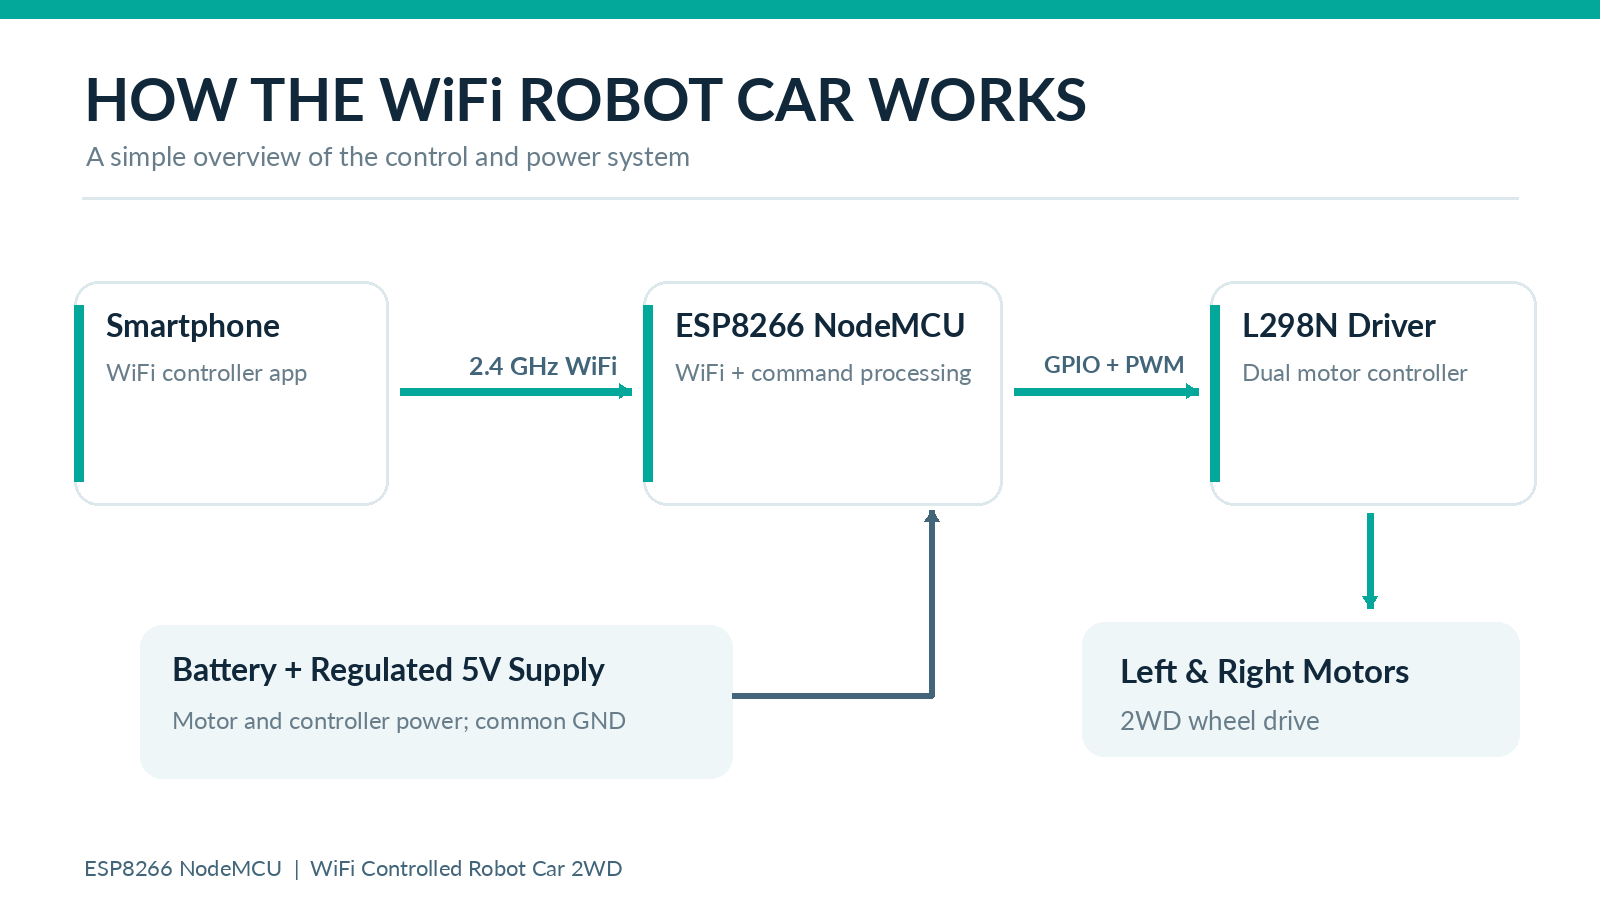
The ESP8266 NodeMCU WiFi Controlled Robot Car 2WD DIY Kit is a practical project for exploring wireless robotics. Built around a two-wheel robot platform, the car combines an ESP8266-based NodeMCU development board with an L298N dual-channel motor driver. Instead of relying on a conventional radio controller, it uses a local WiFi connection to exchange commands with a smartphone or another compatible device. The project is designed for hands-on assembly and experimentation.
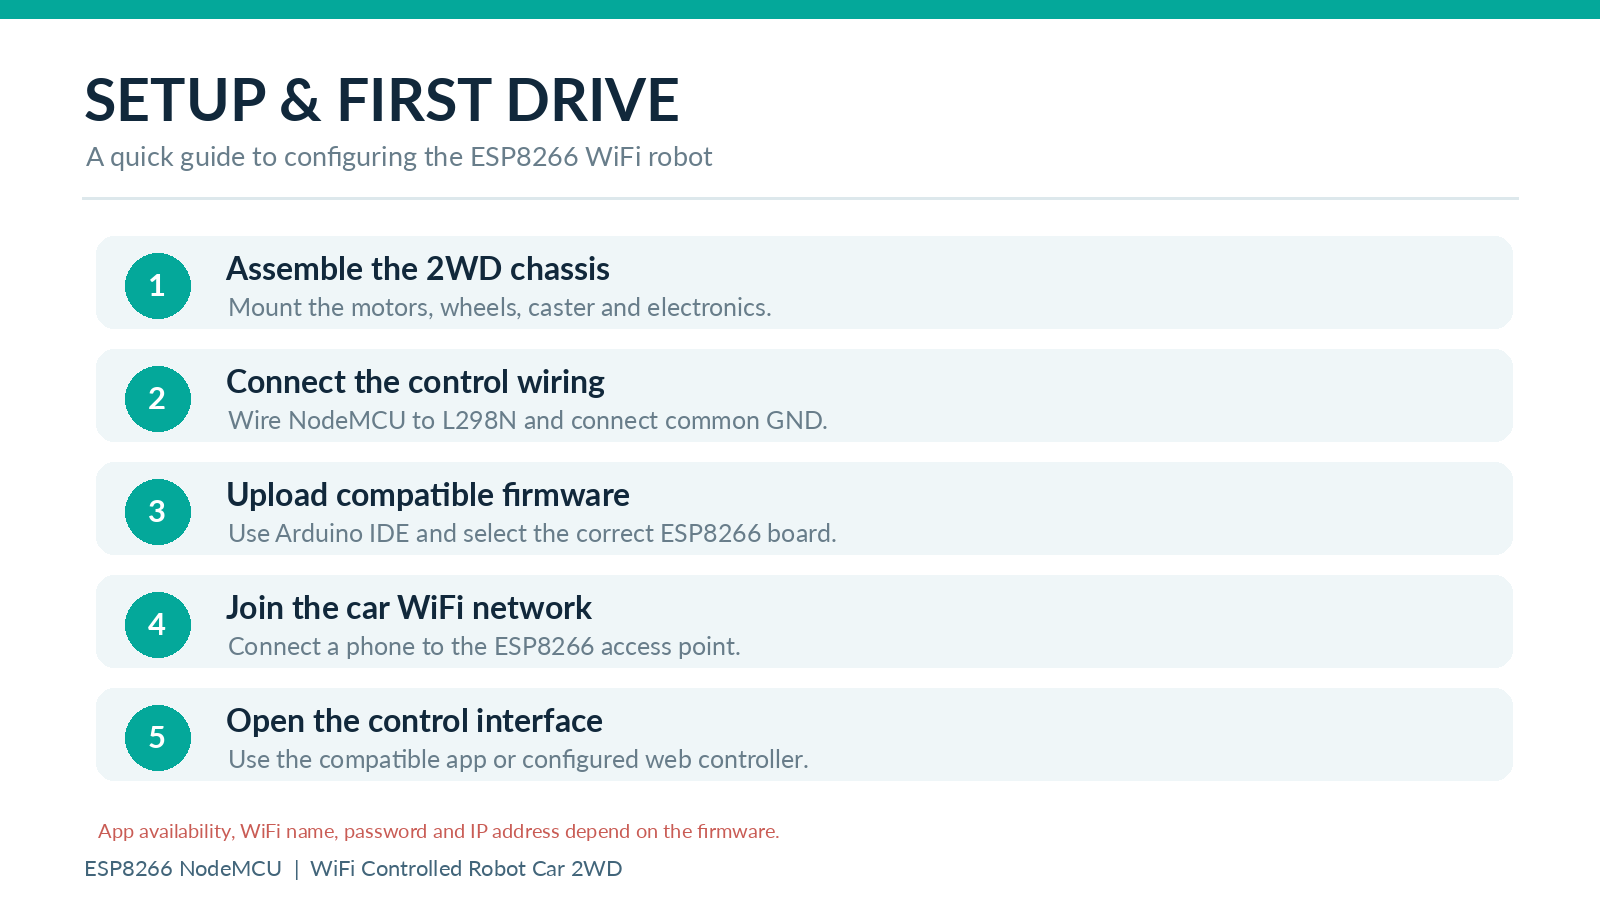
Once the electronics are connected and suitable firmware is uploaded, the NodeMCU interprets incoming control commands and operates the motor driver through its GPIO pins. The L298N controls the left and right geared motors, allowing the vehicle to move forward, reverse, turn, and stop. PWM signals can be used to adjust motor speed. The control interface, network name, and available functions depend on the firmware installed on the board.
Features
- ESP8266 NodeMCU WiFi-enabled development board.
- 2WD robotic car platform with two DC geared motors.
- L298N dual H-bridge motor driver.
- Wireless control using a compatible smartphone interface.
- Forward, backward, left, right, and stop commands.
- PWM motor speed control supported.
- Programmable using Arduino IDE.
- Rechargeable lithium-ion battery power system.
- Modular construction for assembly and experimentation.
- Suitable for educational robotics and IoT projects.
Specifications
| Parameter | Specification |
|---|---|
| Product Type: | WiFi Controlled Robot Car DIY Kit |
| Controller: | ESP8266 NodeMCU Development Board |
| USB Interface Chip: | CH340 |
| Wireless Technology: | WiFi 2.4GHz, IEEE 802.11 b/g/n |
| Control Method: | Smartphone via compatible WiFi control interface |
| Motor Driver: | L298N Dual H-Bridge |
| Drive Configuration: | 2WD (Two-Wheel Drive) |
| DC Motors: | 2 × DC Geared Motors |
| Motor Rated Voltage: | 3–12VDC |
| Motor Rated Speed: | 600 RPM (advertised motor model) |
| Wheel Diameter: | 65mm |
| Wheel Width: | 26mm |
| Robot Platform: | Square 2WD Chassis |
| Chassis Dimensions: | Approximately 200 × 150mm |
| Support Wheel: | Metal Caster Wheel |
| Battery Type: | Rechargeable 18650 Li-ion |
| Battery Quantity: | 2 Cells |
| Individual Battery Voltage: | 3.7V Nominal |
| Individual Battery Capacity: | 1500mAh |
| Battery Holder: | 2-Slot 18650 Holder |
| Battery Charger: | Single-Cell Lithium Battery Charger |
| Motor Control: | Direction Control and PWM Speed Adjustment |
| Programming Interface: | Arduino IDE |
| Assembly: | DIY Assembly Required |
| Wireless Range: | Not Specified |
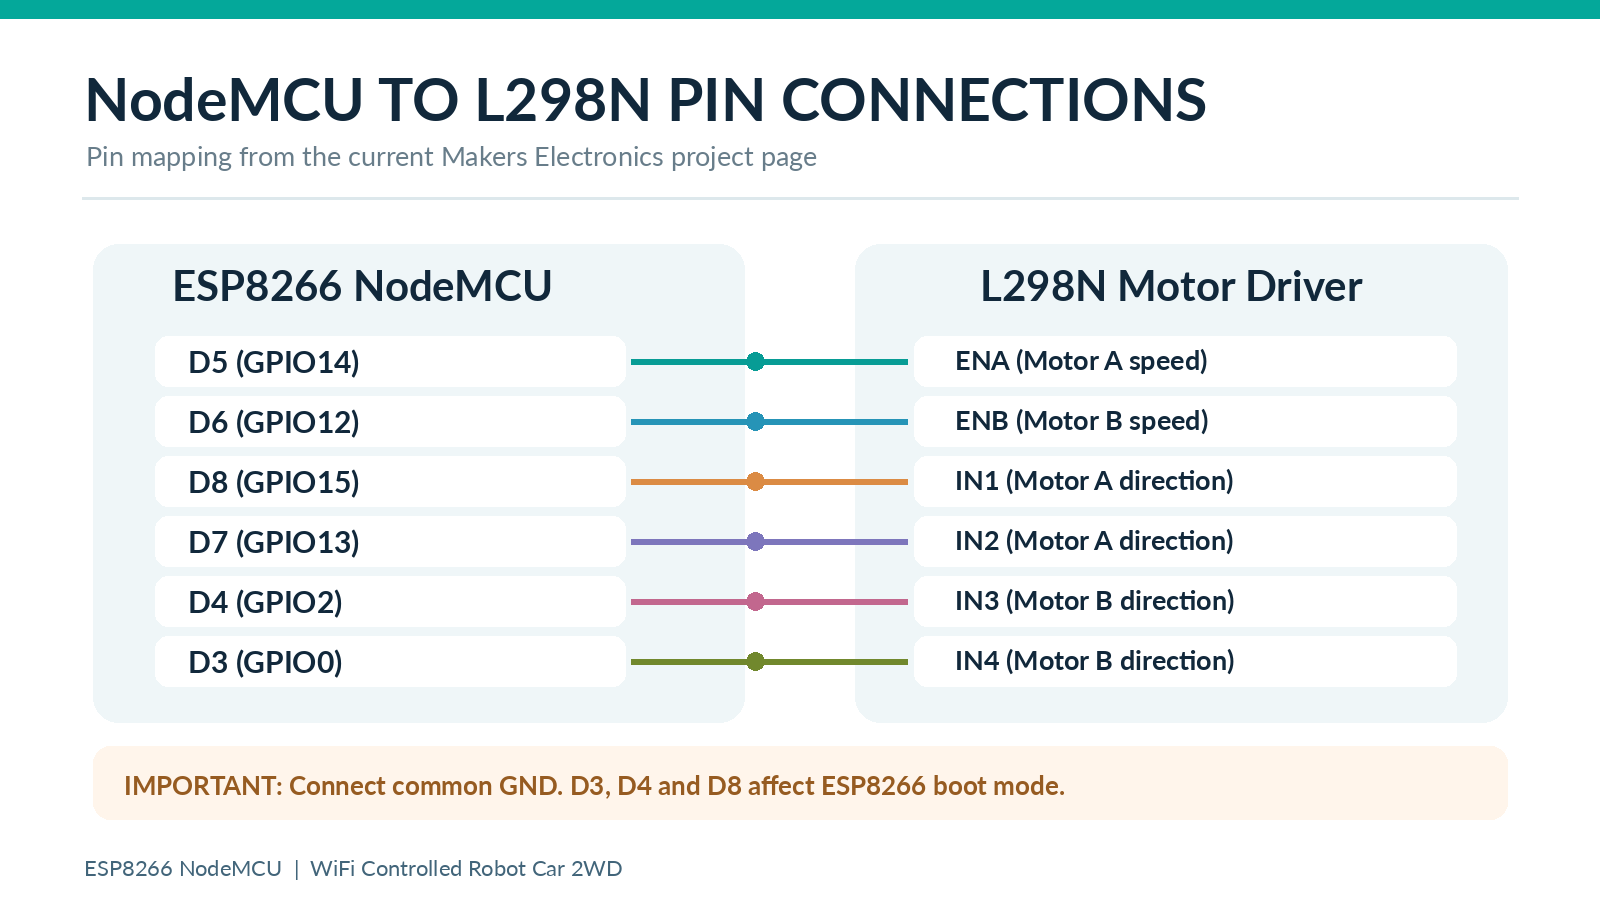
Wiring Connections

Arduino Code & Smartphone Control
| 1 | /* |
| 2 | Code Name: Arduino Wifi Control Car |
| 3 | Code URI: https://circuitbest.com/category/arduino-projects/ |
| 4 | Additional Board Manager URL: http://arduino.esp8266.com/stable/package_esp8266com_index.json |
| 5 | Install: ESP8266 by ESP8266 Community |
| 6 | Author: Make DIY |
| 7 | Author URI: https://circuitbest.com/author/admin/ |
| 8 | Description: This program is used to control a robot using a app |
| 9 | that communicates with Arduino through a ESP8266 Module. |
| 10 | App URI: https://drive.google.com/file/d/1pvtWsTeXhcJdpHMfGlFmbGDuH7eoLfoP/view?usp=sharing |
| 11 | Version: 2.0 |
| 12 | License: Remixing or Changing this Thing is allowed. Commercial use is not allowed. |
| 13 | */ |
| 14 | |
| 15 | |
| 16 | #define ENA 14 // Enable/speed motors Right GPIO14(D5) |
| 17 | #define ENB 12 // Enable/speed motors Left GPIO12(D6) |
| 18 | #define IN_1 15 // L298N in1 motors Rightx GPIO15(D8) |
| 19 | #define IN_2 13 // L298N in2 motors Right GPIO13(D7) |
| 20 | #define IN_3 2 // L298N in3 motors Left GPIO2(D4) |
| 21 | #define IN_4 0 // L298N in4 motors Left GPIO0(D3) |
| 22 | |
| 23 | #include <ESP8266WiFi.h> |
| 24 | #include <WiFiClient.h> |
| 25 | #include <ESP8266WebServer.h> |
| 26 | |
| 27 | String command; //String to store app command state. |
| 28 | int speedCar = 800; // 400 - 1023. |
| 29 | int speed_Coeff = 3; |
| 30 | |
| 31 | const char* ssid = "Make DIY"; |
| 32 | ESP8266WebServer server(80); |
| 33 | |
| 34 | void setup() { |
| 35 | |
| 36 | pinMode(ENA, OUTPUT); |
| 37 | pinMode(ENB, OUTPUT); |
| 38 | pinMode(IN_1, OUTPUT); |
| 39 | pinMode(IN_2, OUTPUT); |
| 40 | pinMode(IN_3, OUTPUT); |
| 41 | pinMode(IN_4, OUTPUT); |
| 42 | |
| 43 | Serial.begin(115200); |
| 44 | |
| 45 | // Connecting WiFi |
| 46 | |
| 47 | WiFi.mode(WIFI_AP); |
| 48 | WiFi.softAP(ssid); |
| 49 | |
| 50 | IPAddress myIP = WiFi.softAPIP(); |
| 51 | Serial.print("AP IP address: "); |
| 52 | Serial.println(myIP); |
| 53 | |
| 54 | // Starting WEB-server |
| 55 | server.on ( "/", HTTP_handleRoot ); |
| 56 | server.onNotFound ( HTTP_handleRoot ); |
| 57 | server.begin(); |
| 58 | } |
| 59 | |
| 60 | void goAhead(){ |
| 61 | |
| 62 | digitalWrite(IN_1, LOW); |
| 63 | digitalWrite(IN_2, HIGH); |
| 64 | analogWrite(ENA, speedCar); |
| 65 | |
| 66 | digitalWrite(IN_3, LOW); |
| 67 | digitalWrite(IN_4, HIGH); |
| 68 | analogWrite(ENB, speedCar); |
| 69 | } |
| 70 | |
| 71 | void goBack(){ |
| 72 | |
| 73 | digitalWrite(IN_1, HIGH); |
| 74 | digitalWrite(IN_2, LOW); |
| 75 | analogWrite(ENA, speedCar); |
| 76 | |
| 77 | digitalWrite(IN_3, HIGH); |
| 78 | digitalWrite(IN_4, LOW); |
| 79 | analogWrite(ENB, speedCar); |
| 80 | } |
| 81 | |
| 82 | void goRight(){ |
| 83 | |
| 84 | digitalWrite(IN_1, HIGH); |
| 85 | digitalWrite(IN_2, LOW); |
| 86 | analogWrite(ENA, speedCar); |
| 87 | |
| 88 | digitalWrite(IN_3, LOW); |
| 89 | digitalWrite(IN_4, HIGH); |
| 90 | analogWrite(ENB, speedCar); |
| 91 | } |
| 92 | |
| 93 | void goLeft(){ |
| 94 | |
| 95 | digitalWrite(IN_1, LOW); |
| 96 | digitalWrite(IN_2, HIGH); |
| 97 | analogWrite(ENA, speedCar); |
| 98 | |
| 99 | digitalWrite(IN_3, HIGH); |
| 100 | digitalWrite(IN_4, LOW); |
| 101 | analogWrite(ENB, speedCar); |
| 102 | } |
| 103 | |
| 104 | void goAheadRight(){ |
| 105 | |
| 106 | digitalWrite(IN_1, LOW); |
| 107 | digitalWrite(IN_2, HIGH); |
| 108 | analogWrite(ENA, speedCar/speed_Coeff); |
| 109 | |
| 110 | digitalWrite(IN_3, LOW); |
| 111 | digitalWrite(IN_4, HIGH); |
| 112 | analogWrite(ENB, speedCar); |
| 113 | } |
| 114 | |
| 115 | void goAheadLeft(){ |
| 116 | |
| 117 | digitalWrite(IN_1, LOW); |
| 118 | digitalWrite(IN_2, HIGH); |
| 119 | analogWrite(ENA, speedCar); |
| 120 | |
| 121 | digitalWrite(IN_3, LOW); |
| 122 | digitalWrite(IN_4, HIGH); |
| 123 | analogWrite(ENB, speedCar/speed_Coeff); |
| 124 | } |
| 125 | |
| 126 | void goBackRight(){ |
| 127 | |
| 128 | digitalWrite(IN_1, HIGH); |
| 129 | digitalWrite(IN_2, LOW); |
| 130 | analogWrite(ENA, speedCar/speed_Coeff); |
| 131 | |
| 132 | digitalWrite(IN_3, HIGH); |
| 133 | digitalWrite(IN_4, LOW); |
| 134 | analogWrite(ENB, speedCar); |
| 135 | } |
| 136 | |
| 137 | void goBackLeft(){ |
| 138 | |
| 139 | digitalWrite(IN_1, HIGH); |
| 140 | digitalWrite(IN_2, LOW); |
| 141 | analogWrite(ENA, speedCar); |
| 142 | |
| 143 | digitalWrite(IN_3, HIGH); |
| 144 | digitalWrite(IN_4, LOW); |
| 145 | analogWrite(ENB, speedCar/speed_Coeff); |
| 146 | } |
| 147 | |
| 148 | void stopRobot(){ |
| 149 | |
| 150 | digitalWrite(IN_1, LOW); |
| 151 | digitalWrite(IN_2, LOW); |
| 152 | analogWrite(ENA, speedCar); |
| 153 | |
| 154 | digitalWrite(IN_3, LOW); |
| 155 | digitalWrite(IN_4, LOW); |
| 156 | analogWrite(ENB, speedCar); |
| 157 | } |
| 158 | |
| 159 | void loop() { |
| 160 | server.handleClient(); |
| 161 | |
| 162 | command = server.arg("State"); |
| 163 | if (command == "F") goAhead(); |
| 164 | else if (command == "B") goBack(); |
| 165 | else if (command == "L") goLeft(); |
| 166 | else if (command == "R") goRight(); |
| 167 | else if (command == "I") goAheadRight(); |
| 168 | else if (command == "G") goAheadLeft(); |
| 169 | else if (command == "J") goBackRight(); |
| 170 | else if (command == "H") goBackLeft(); |
| 171 | else if (command == "0") speedCar = 400; |
| 172 | else if (command == "1") speedCar = 470; |
| 173 | else if (command == "2") speedCar = 540; |
| 174 | else if (command == "3") speedCar = 610; |
| 175 | else if (command == "4") speedCar = 680; |
| 176 | else if (command == "5") speedCar = 750; |
| 177 | else if (command == "6") speedCar = 820; |
| 178 | else if (command == "7") speedCar = 890; |
| 179 | else if (command == "8") speedCar = 960; |
| 180 | else if (command == "9") speedCar = 1023; |
| 181 | else if (command == "S") stopRobot(); |
| 182 | } |
| 183 | |
| 184 | void HTTP_handleRoot(void) { |
| 185 | |
| 186 | if( server.hasArg("State") ){ |
| 187 | Serial.println(server.arg("State")); |
| 188 | } |
| 189 | server.send ( 200, "text/html", "" ); |
| 190 | delay(1); |
| 191 | } |
How to Program and Control the ESP8266 WiFi Robot Car
Step 1: Install and Configure Arduino IDE
- Download the Arduino code provided for the ESP8266 WiFi Robot Car.
- Open Arduino IDE and navigate to File > New to create a new sketch.
- Delete the existing code and paste the downloaded Arduino code into the editor.
- Open Arduino IDE Preferences:
- Windows: File > Preferences
- macOS: Arduino IDE > Settings/Preferences
- Copy the following URL and paste it into the Additional Boards Manager URLs field:
Additional Boards Manager URL:
http://arduino.esp8266.com/stable/package_esp8266com_index.json - Click OK to save the settings.
- Navigate to Tools > Board > Boards Manager.
- Search for ESP8266 and install the ESP8266 by ESP8266 Community board package.
- Go to Tools > Board > ESP8266 Boards and select NodeMCU 1.0 (ESP-12E Module) for a compatible NodeMCU development board.
- Connect the NodeMCU to your computer using a USB data cable.
- Select the correct COM Port (Windows) or serial port (macOS) from Tools > Port.
- Click Verify to compile the code and check for errors.
- Click Upload to transfer the program to the NodeMCU board.
- Once the upload is complete, disconnect the USB cable and prepare the robot car for operation.
Step 2: Connect and Control the Robot Car
- Make sure all components are correctly connected according to the wiring diagram.
- Connect the battery power supply to the robot car.
- Download and install the smartphone control application compatible with the uploaded Arduino code.
- Open your smartphone’s WiFi Settings.
- Search for the WiFi network created by the ESP8266. In the original project firmware, the default SSID is Make DIY.
- Connect your smartphone to the ESP8266 WiFi network.
- Open the compatible control application.
- Use the directional buttons to move the robot car Forward, Backward, Left, or Right, or to stop it.
- Use the Speed Slider, if supported by the uploaded firmware and application, to adjust the motor speed.
Note: The WiFi network name, control application, and available features depend on the uploaded Arduino firmware. The SSID can be customized by modifying the corresponding value in the code.
Step 3: Troubleshooting
Problem: Robot Car Moves in the Wrong Direction
If the robot car moves backward when pressing the Forward button, or turns unexpectedly, follow these steps:
- Position the robot car facing forward.
- Lift the wheels off the ground and press the Forward button.
- Check the rotation direction of both motors.
- If a motor rotates in the wrong direction, disconnect the power supply.
- Reverse the two motor wires connected to the corresponding motor output terminals on the L298N motor driver.
- Reconnect the power supply and test the robot car again.
Important Notes:
- Ensure that the NodeMCU, L298N motor driver, and motors are properly connected before applying power.
- Use a suitable power supply for the NodeMCU and motors.
- Verify that the correct ESP8266 board and serial port are selected before uploading the code.
- Make sure the smartphone control application is compatible with the uploaded firmware.
- Always disconnect the power supply before changing motor connections.
Applications
- Educational Robotics Projects.
- WiFi-Controlled Vehicle Projects.
- IoT Learning and Prototyping.
- Wireless Motor Control Experiments.
- STEM Education Projects.
- Embedded Systems Programming.
- DIY Robotic Vehicle Development.
Package Contents
- 1× ESP8266 NodeMCU Development Board with CH340
- 1× L298N Motor Driver Module
- 1× Robot Platform 2WD Square Shape
- 2× DC Geared Motors with Wheels
- 1× Metal Caster Wheel
- 1× 18650 Battery Holder (2-Slot)
- 2× Rechargeable 18650 Li-ion Batteries 3.7V 1500mAh
- 1× Universal Lithium Battery Charger (1 Cell)
- 10× Jumper Wires 20cm (Male to Female)
- 10× Jumper Wires 20cm (Female to Female)
- 2× 30 AWG Wrapping Wire Units
Note: The following tools and materials are required for assembling the ESP8266 WiFi Controlled Robot Car and are not included in the package:
- Soldering Iron
- Solder Wire
- Soldering Flux
- Screwdriver
- Double-Sided Tape
App Link: Download